
First Pass for Engineers: Lumped Capacitance + 2 Worked Examples

Lumped capacitance is a simplified heat transfer model that treats an object as having one uniform internal temperature at any instant, collapsing a partial differential equation into a first-order ODE with an exponential solution. It applies whenever the Biot number, Bi = hLc/k, stays below roughly 0.1, meaning internal conduction resistance is negligible compared to surface convection resistance. When that check passes, you get a clean exponential temperature curve and a time constant, τ = ρcₚV/(hAs), that tells you exactly how fast the object heats or cools.
TL;DR:
The lumped capacitance model applies only if the Biot number is below approximately 0.1, indicating internal conduction is much faster than surface convection.
Accurate estimation of the convective coefficient and the characteristic length is crucial, as errors can lead to invalid assumptions and inaccurate temperature predictions.
The exponential temperature change depends on a time constant calculated from the object’s properties and surface conditions, simplifying transient cooling or heating analysis.
For borderline Biot numbers or complex scenarios, validating lumped results against numerical or CFD models prevents mistakes from geometric or flow uncertainties.
The method is most reliable for high-conductivity objects and thick geometries, while it fails when internal temperature gradients become significant and multi-lump models or CFD are necessary.
Table of Contents
What Is Lumped Capacitance and When Does It Apply?
The lumped capacitance method works because of one assumption: temperature gradients inside the object are small enough to ignore. Instead of tracking how heat moves through the material point by point, you treat the whole mass as a single “lump” at a single temperature. That assumption only holds when conduction inside the object happens much faster than convection can pull heat off its surface.
The test for that is the Biot number:
Bi = hLc / k
Here, h is the convective heat transfer coefficient (W/m²K), k is the thermal conductivity of the solid (W/mK), and Lc is the characteristic length, defined as Lc = V/As (volume divided by surface area). This ratio matters more than it looks. Bi is really a comparison of two resistances: conduction resistance inside the body versus convection resistance at its surface. A low Bi means the surface is the bottleneck, not the interior, so the interior stays close to uniform.
The widely used rule of thumb sets the cutoff at Bi < 0.1. Above 0.1, gradients inside the object become significant enough that a single temperature value stops representing reality.
Borderline cases (Bi between 0.1 and roughly 0.2 to 0.3) deserve caution rather than automatic rejection. Some research on extending the method’s validity shows lumped models can still track transient behavior reasonably well at higher Bi, depending on geometry and how the transient unfolds. But you should never accept that on faith. Check it against a numerical or analytical alternative before trusting the result.
Estimating h and k accurately is where most errors creep in. k comes from material property tables and rarely shifts much unless temperature swings are extreme. h is the harder number: free convection in still air typically runs low, forced convection with a fan or flowing liquid runs much higher, and boiling or condensation can push it higher still. Geometric approximations for Lc also matter. A sphere, a long cylinder, and a thin plate each have different V/As ratios, and using the wrong one skews Bi in a direction that can hide a bad assumption.
Define Bi = hLc/k and compute Lc as V/As for your actual geometry, not a rough guess.
Treat Bi < 0.1 as a conservative green light, not a hard law of physics.
Re-check h whenever flow conditions change (fan speed, fluid velocity, orientation).
Validate borderline Bi values against a numerical solution before committing to lumped results.
Pro Tip: When you’re not sure which convection regime applies, calculate Bi twice using the low and high end of a plausible h range. If both give Bi well under 0.1, you’re safe. If the answer flips depending on which h you pick, that’s your signal to get a firmer number for h before trusting the model.
How Do You Derive the Exponential Temperature Equation?
Once Bi confirms the lumped assumption, the math gets simple. Start with an energy balance on the whole object: the rate of heat leaving the surface by convection equals the rate its internal energy drops.
That balance is written as:
ρVcₚ (dT/dt) = -hAs (T - T∞)
Rearranging gives the governing ODE:
dT/dt = -(hAs)/(ρVcₚ) · (T - T∞)
where ρ is density, cₚ is specific heat, V is volume, As is surface area, and T∞ is the ambient (fluid) temperature. This is a first-order linear ODE, and its structure should look familiar: it says the rate of temperature change is proportional to how far the object is from equilibrium. The bigger the gap, the faster it closes.
Solving that ODE with the initial condition T(0) = T0 gives the standard exponential solution, sometimes called Newton’s law of cooling in its transient form:
(T(t) - T∞) / (T0 - T∞) = e^(-t/τ)
The time constant, τ, is defined as:
τ = ρcₚV / (hAs)
τ has units of time (seconds, typically) and controls everything about how fast the curve moves. A small τ means the object reaches ambient temperature quickly; a large τ means it lags. Physically, τ is the product of a “thermal resistance” term (1/hAs) and a “thermal capacitance” term (ρcₚV), which is exactly why the method is called lumped capacitance. It borrows the same math structure used in lumped circuit models in electrical engineering, where a capacitor charges or discharges on an RC time constant. The thermal and electrical versions are mathematically identical, just with different variable names.
A few notes worth keeping straight:
The sign convention assumes T0 > T∞ for cooling; the same equation works for heating with T0 < T∞, since the exponential naturally handles the direction.
Some references write τ using mass (m = ρV) instead of density and volume separately; both forms are equivalent.
τ relates to the dimensionless Fourier number (Fo = αt/Lc²), which shows up in more general transient conduction problems and confirms that lumped analysis is really just a special, simplified case of that broader family.
How Do You Calculate Time Constant and Solve for Target Temperature?
Once you trust the Biot check, the actual calculation is mechanical. Here’s the sequence engineers use in practice:
Gather your inputs: density (ρ), specific heat (cₚ), volume (V), surface area (As), convective coefficient (h), initial temperature (T0), and ambient temperature (T∞).
Compute the characteristic length: Lc = V/As, then check Bi = hLc/k against 0.1.
Compute the time constant: τ = ρcₚV/(hAs).
Solve for temperature at a given time, or invert the equation to solve for time at a given temperature target:
t = -τ ln[(T(t) - T∞) / (T0 - T∞)]
This inversion is where the method earns its keep for design work. Instead of asking “what temperature will this be after 10 minutes,” you can ask “how long until this part cools to 50°C,” and get a direct answer without iterating.
Getting h right is usually the weak link. As a rough qualitative guide, free convection in air tends to sit at the low end of typical ranges, forced convection with fans or pumped air runs noticeably higher, and liquid convection, especially forced or boiling, runs highest of all. These ranges vary enormously with geometry and flow velocity, so treat any generic number as a starting estimate, not a substitute for a correlation or a manufacturer’s data sheet.
Statistic Callout: The Bi < 0.1 threshold is the single most cited validity rule across university thermal science courses, and it remains the fastest sanity check available before running any transient simulation.
Common pitfalls worth flagging before you trust an answer:
Mixing units between SI and imperial mid-calculation, especially with h values pulled from different sources.
Using the wrong surface area definition (total exposed area versus area in contact with the convecting fluid only).
Forgetting that cₚ and k can shift meaningfully with temperature for some materials, which breaks the “constant properties” assumption baked into the ODE.
Applying a still-air h value to a scenario that actually has airflow, which can throw τ off by an order of magnitude.
Two Worked Examples: Solving for Bi, τ, and T(t)
Example 1: Small aluminum sphere cooling in air
A solid aluminum sphere with a 2 cm diameter (radius r = 0.01 m) starts at 200°C and cools in still air at 20°C. Aluminum properties: k ≈ 205 W/mK, ρ ≈ 2,700 kg/m³, cₚ ≈ 900 J/kgK. Assume a free convection coefficient h ≈ 10 W/m²K.
Bi comes out at roughly 0.00016, far below 0.1, so the lumped assumption is solid here. Aluminum’s high conductivity is doing most of the work. To find how long it takes to cool to 50°C, invert the exponential:
t = -τ ln[(50-20)/(200-20)] = -806 × ln(0.1667) ≈ 806 × 1.79 ≈ 1,443 seconds (about 24 minutes)
Example 2: Well-stirred water in a small metal cup
A small cup holds 200 mL of water (V = 2 × 10⁻⁴ m³) at 90°C, cooling in a room at 22°C through natural convection off the cup’s exposed surface (As ≈ 0.015 m², h ≈ 8 W/m²K). Water properties: ρ ≈ 1,000 kg/m³, cₚ ≈ 4,186 J/kgK, k ≈ 0.6 W/mK.
Because the liquid is treated as well-stirred (effectively isothermal by mixing rather than by high conductivity), the Biot check uses a modified logic: internal mixing, not conduction, keeps the fluid uniform. Using the container’s own characteristic length, Lc = V/As ≈ 0.0133 m, gives Bi = hLc/k ≈ 0.178, which sits above the conservative 0.1 threshold. In practice, engineers accept this for well-mixed fluids because convective stirring, not conduction through water, is what equalizes temperature, but it’s a case where you’d flag the assumption rather than accept it blindly.
τ = ρcₚV/(hAs) = (1,000 × 4,186 × 2×10⁻⁴)/(8 × 0.015) ≈ 837.2/0.12 ≈ 6,977 seconds (about 1.94 hours)
That long τ makes sense: water’s high specific heat means it holds onto thermal energy far longer than the aluminum sphere did, even with a comparable convective coefficient.
Rounding choices matter more than they seem. Round Lc up and Bi creeps closer to the 0.1 line; round h down and τ stretches out considerably. Always carry a couple of extra significant figures through the intermediate steps and round only at the final answer.
When Does Lumped Capacitance Fail, and What Should You Use Instead?
The method breaks down as Bi climbs, because the whole premise, a single representative temperature, stops matching physical reality. Larger Bi means the object’s surface cools or heats noticeably faster than its core, and the resulting internal gradient is exactly what the lumped model assumes away. Geometrically, this shows up fastest in thick, low-conductivity objects like insulating plastics or thick ceramic parts, and least in thin, high-conductivity metals.
When Bi creeps past the safe zone, you have three practical escalation paths:
Multi-lump discretization: split the object into several nodes, each individually satisfying Bi < 0.1, which converts the PDE into a small system of coupled ODEs solvable with basic matrix methods. This keeps most of the speed advantage while capturing first-order spatial gradients.
Finite-difference or analytical series solutions: appropriate when you need a full temperature profile through the object’s thickness, not just a bulk average, and when a rough multi-lump split isn’t precise enough.
Full CFD simulation: worth the added cost and setup time when convection itself is complex, flow is not well characterized, or the geometry is too irregular for a clean Lc estimate. Our guide to mapping governing equations to solver setup walks through that transition in more detail.
If you’re on the fence about a borderline Bi, don’t rely on the rule of thumb alone. Compare your lumped result against a 1D transient numerical solution or a short CFD run to quantify the actual error before trusting the faster method for a real design decision.
Pro Tip: If a multi-lump model still shows meaningfully different temperatures between adjacent nodes after a few iterations, that’s your signal the geometry needs finer resolution, not just more nodes bolted onto the same coarse split.
How We Use Lumped Capacitance as a First Screening Step
Every transient thermal problem crossing our desk starts the same way: quick estimate, Biot check, then a decision. If Bi clears 0.1 comfortably, the exponential solution gives us a defensible answer in minutes. If it doesn’t, we subdivide into lumps or escalate to CFD, but only after the cheap check tells us that’s necessary. Skipping straight to CFD wastes hours on problems a hand calculation would have settled.
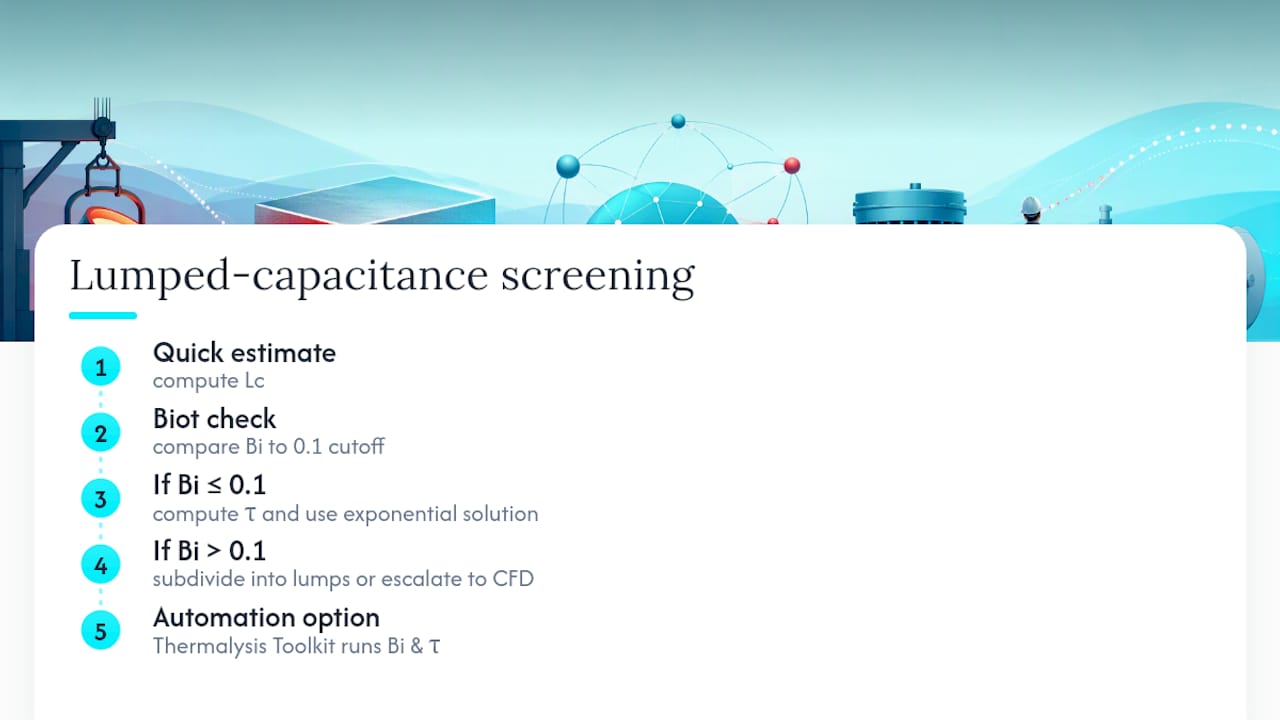
The Thermalysis Toolkit from Jewlztech automates that first pass, running the Bi and τ calculations alongside full transient simulations so you’re not re-deriving the same ODE for every new geometry. It’s a workflow shortcut, not a replacement for understanding why the math works.
Checklist: compute Lc, check Bi, compute τ, solve for t, and only escalate when the numbers tell you to.
— Joel
Sources
The formulas, thresholds, and worked-example structure in this guide draw on established engineering references. BYU’s ME340 lumped capacitance tables provide the formula sheets and numeric templates used across coursework. The Wikipedia entry on lumped-element models covers the underlying derivation and its shared math with electrical circuit theory. MyEngineeringTools breaks down the stepwise recipe for practical use, and Fiveable’s summary of lumped system analysis frames the Biot number as the core go/no-go test taught in transient heat transfer courses.
Recommended
Comments